Precision Agricultural Spraying
Autonomous computer vision for tractor-mounted sprayer nozzles: detect crop rows, spray only what matters, cut pesticide waste.
Overview
Blanket pesticide spraying wastes chemicals and contaminates soil. This system uses computer vision on a Raspberry Pi 4 to detect crop rows in real time and map them to individual sprayer nozzles, so only the targeted sections are sprayed.
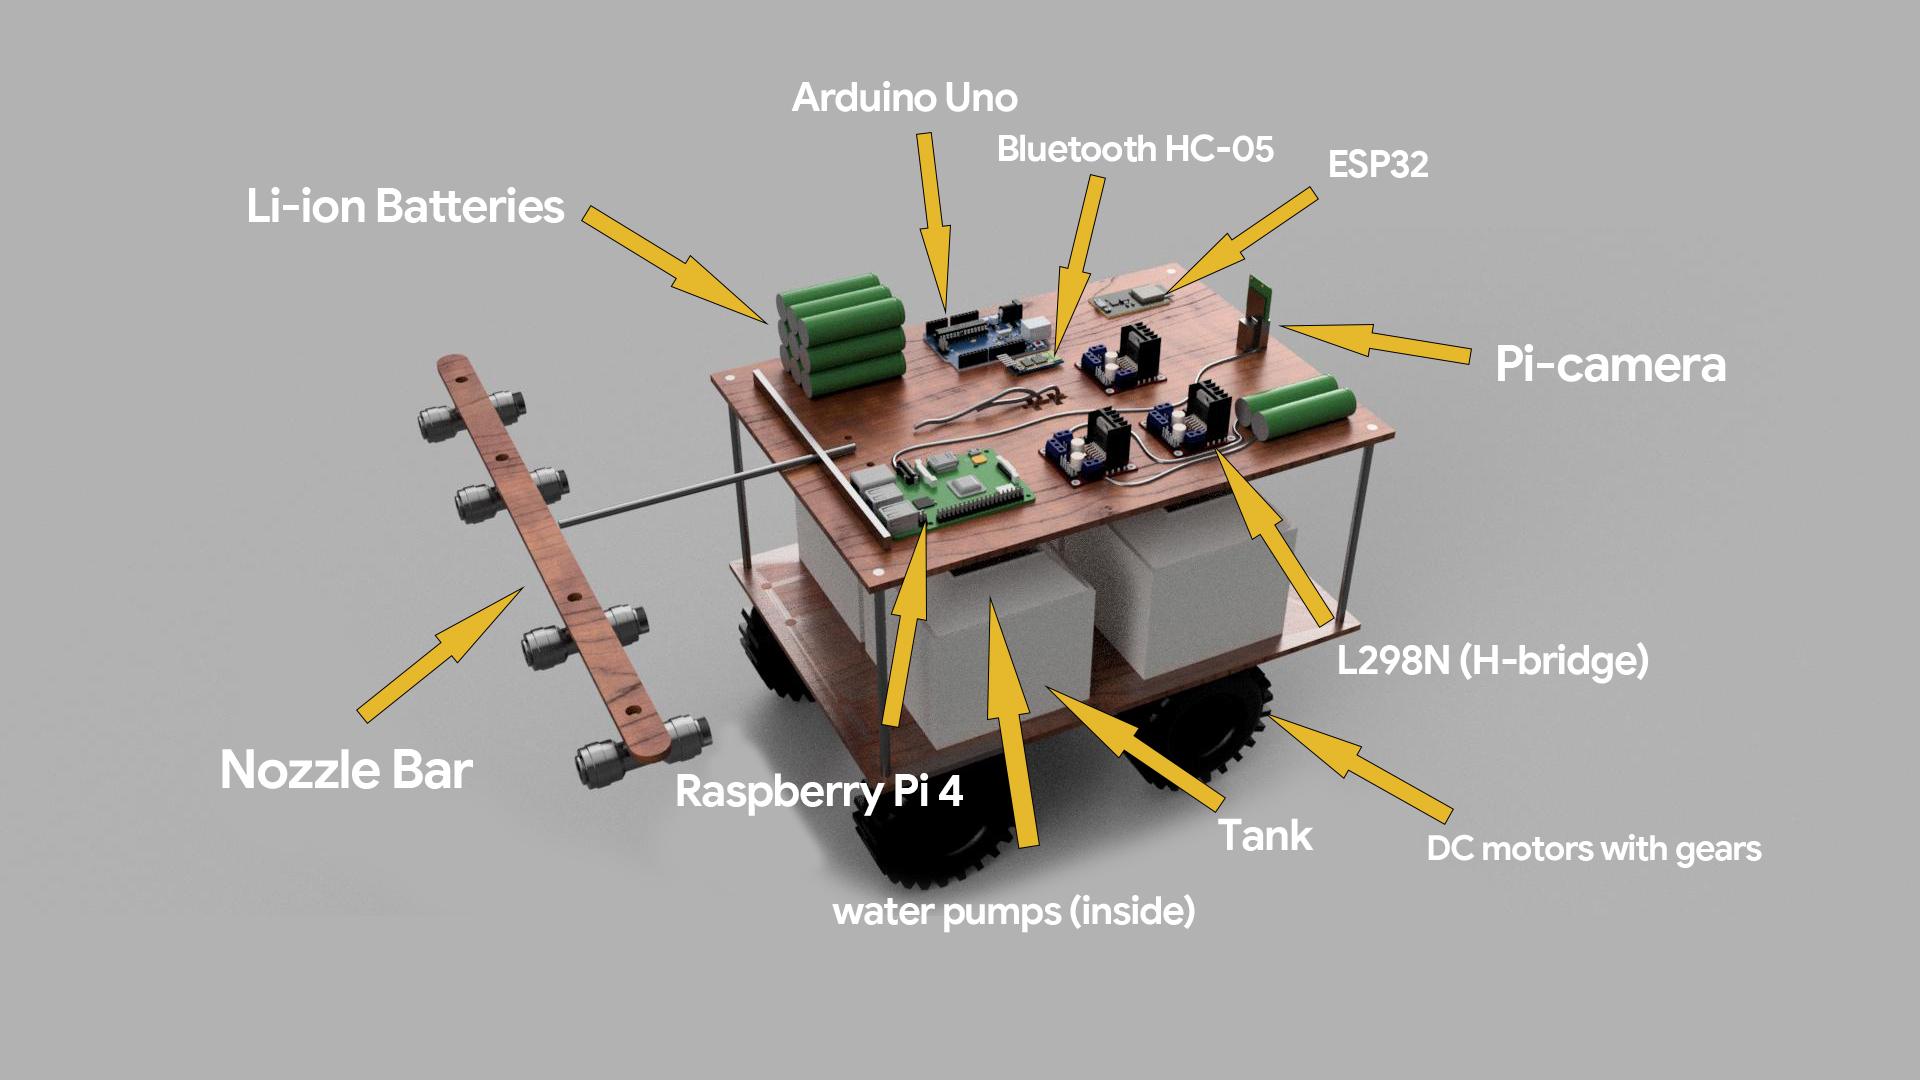
I built the full pipeline from camera to nozzle: the vision algorithm, the nozzle-mapping logic, and the hardware control across an Arduino Uno and an ESP32. A prototype vehicle can be driven and monitored remotely from a phone.
- Year
- 2024
- Area
- AI & Vision
- Role
- Computer vision & embedded engineering
Stack
- Python
- Computer Vision
- Raspberry Pi 4
- Arduino
- ESP32
- Blynk
Crop row detection
A vision pipeline on Raspberry Pi 4 that locates crop rows and converts them into nozzle activation signals.
Nozzle control
An Arduino Uno fires nozzles precisely over the targeted crop sections.
Remote operation
An ESP32 links to the Blynk IoT cloud for motor control, with an MIT App Inventor app for the pumps.
Hardware build
L298N motor drivers, Li-ion power, an HC-05 Bluetooth module and a 3D-designed prototype.